
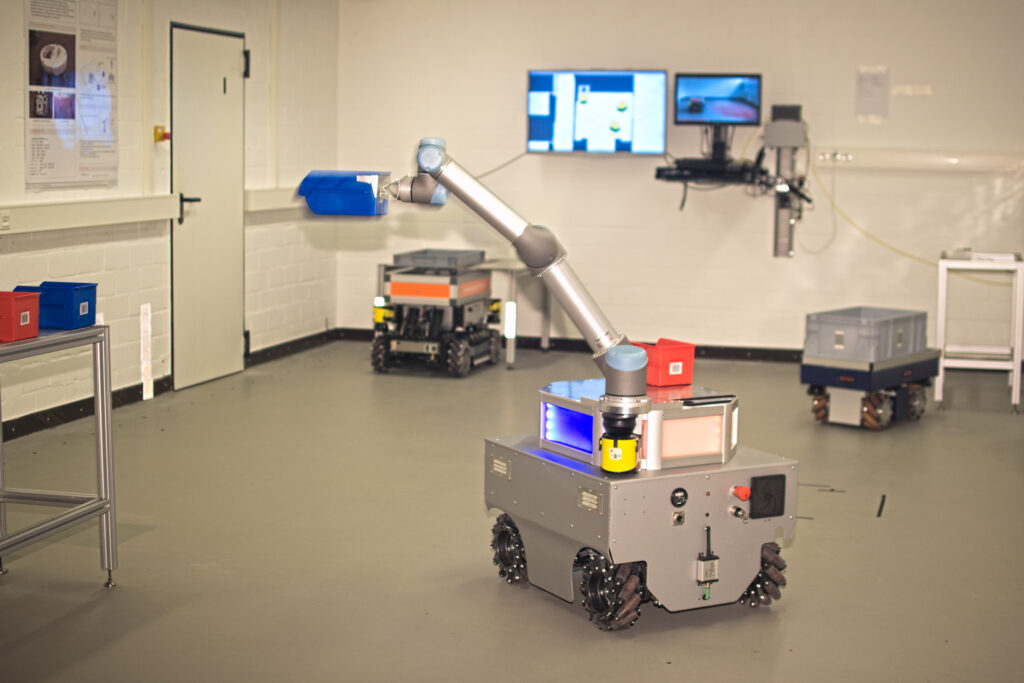
OmniMan is the IMSL’s omnidirectional mobile manipulator. It consists of a mobile robot base and a robotic arm.
Entstehung
OmniMan was developed as part of the OmniMan project – System Architecture for a Mobile Omnidirectional Manipulator and has also been used and expanded in other projects, such as IMeRo – Customized Human-Robot Collaboration for the Workplace in the Face of Demographic Change. In addition to its use in research projects, Omni is also utilized in students’ seminar papers and theses, thereby being expanded to include new sensors and actuators.
